Aerial detection & object counting
An aerial image pipeline for detecting people and vehicles, displaying image-level counts, and exploring optional video tracking.
Problem & method
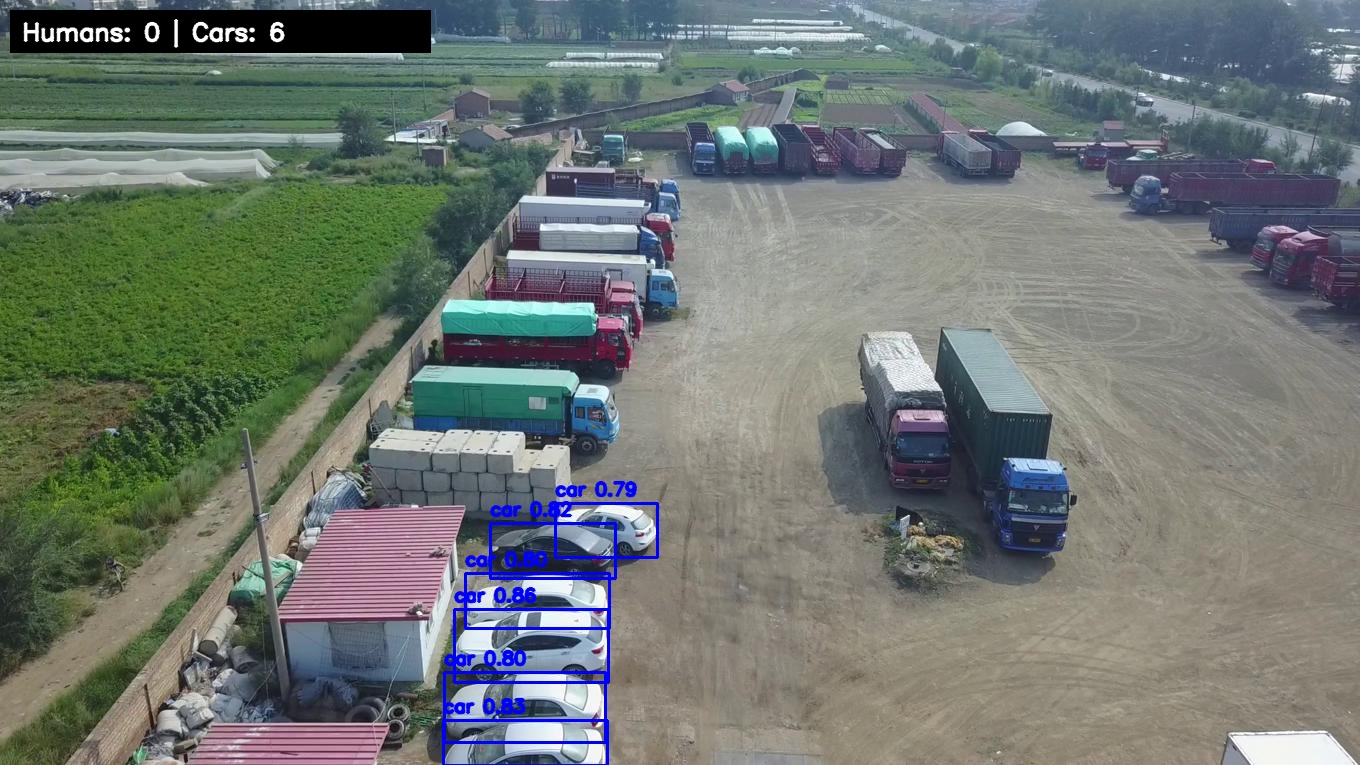
Small objects, occlusion, crowded scenes, and similar vehicle classes make aerial detection difficult. The project uses the VisDrone dataset and a YOLO11n model, trained on all ten dataset classes. The final image output filters to pedestrians, people, and cars.
Human counts are computed from pedestrian and people detections in each image. Optional ByteTrack integration visualizes tracking IDs across video frames.
Reported evaluation
| Metric | Value in project record |
|---|---|
| Precision | 0.510 |
| Recall | 0.404 |
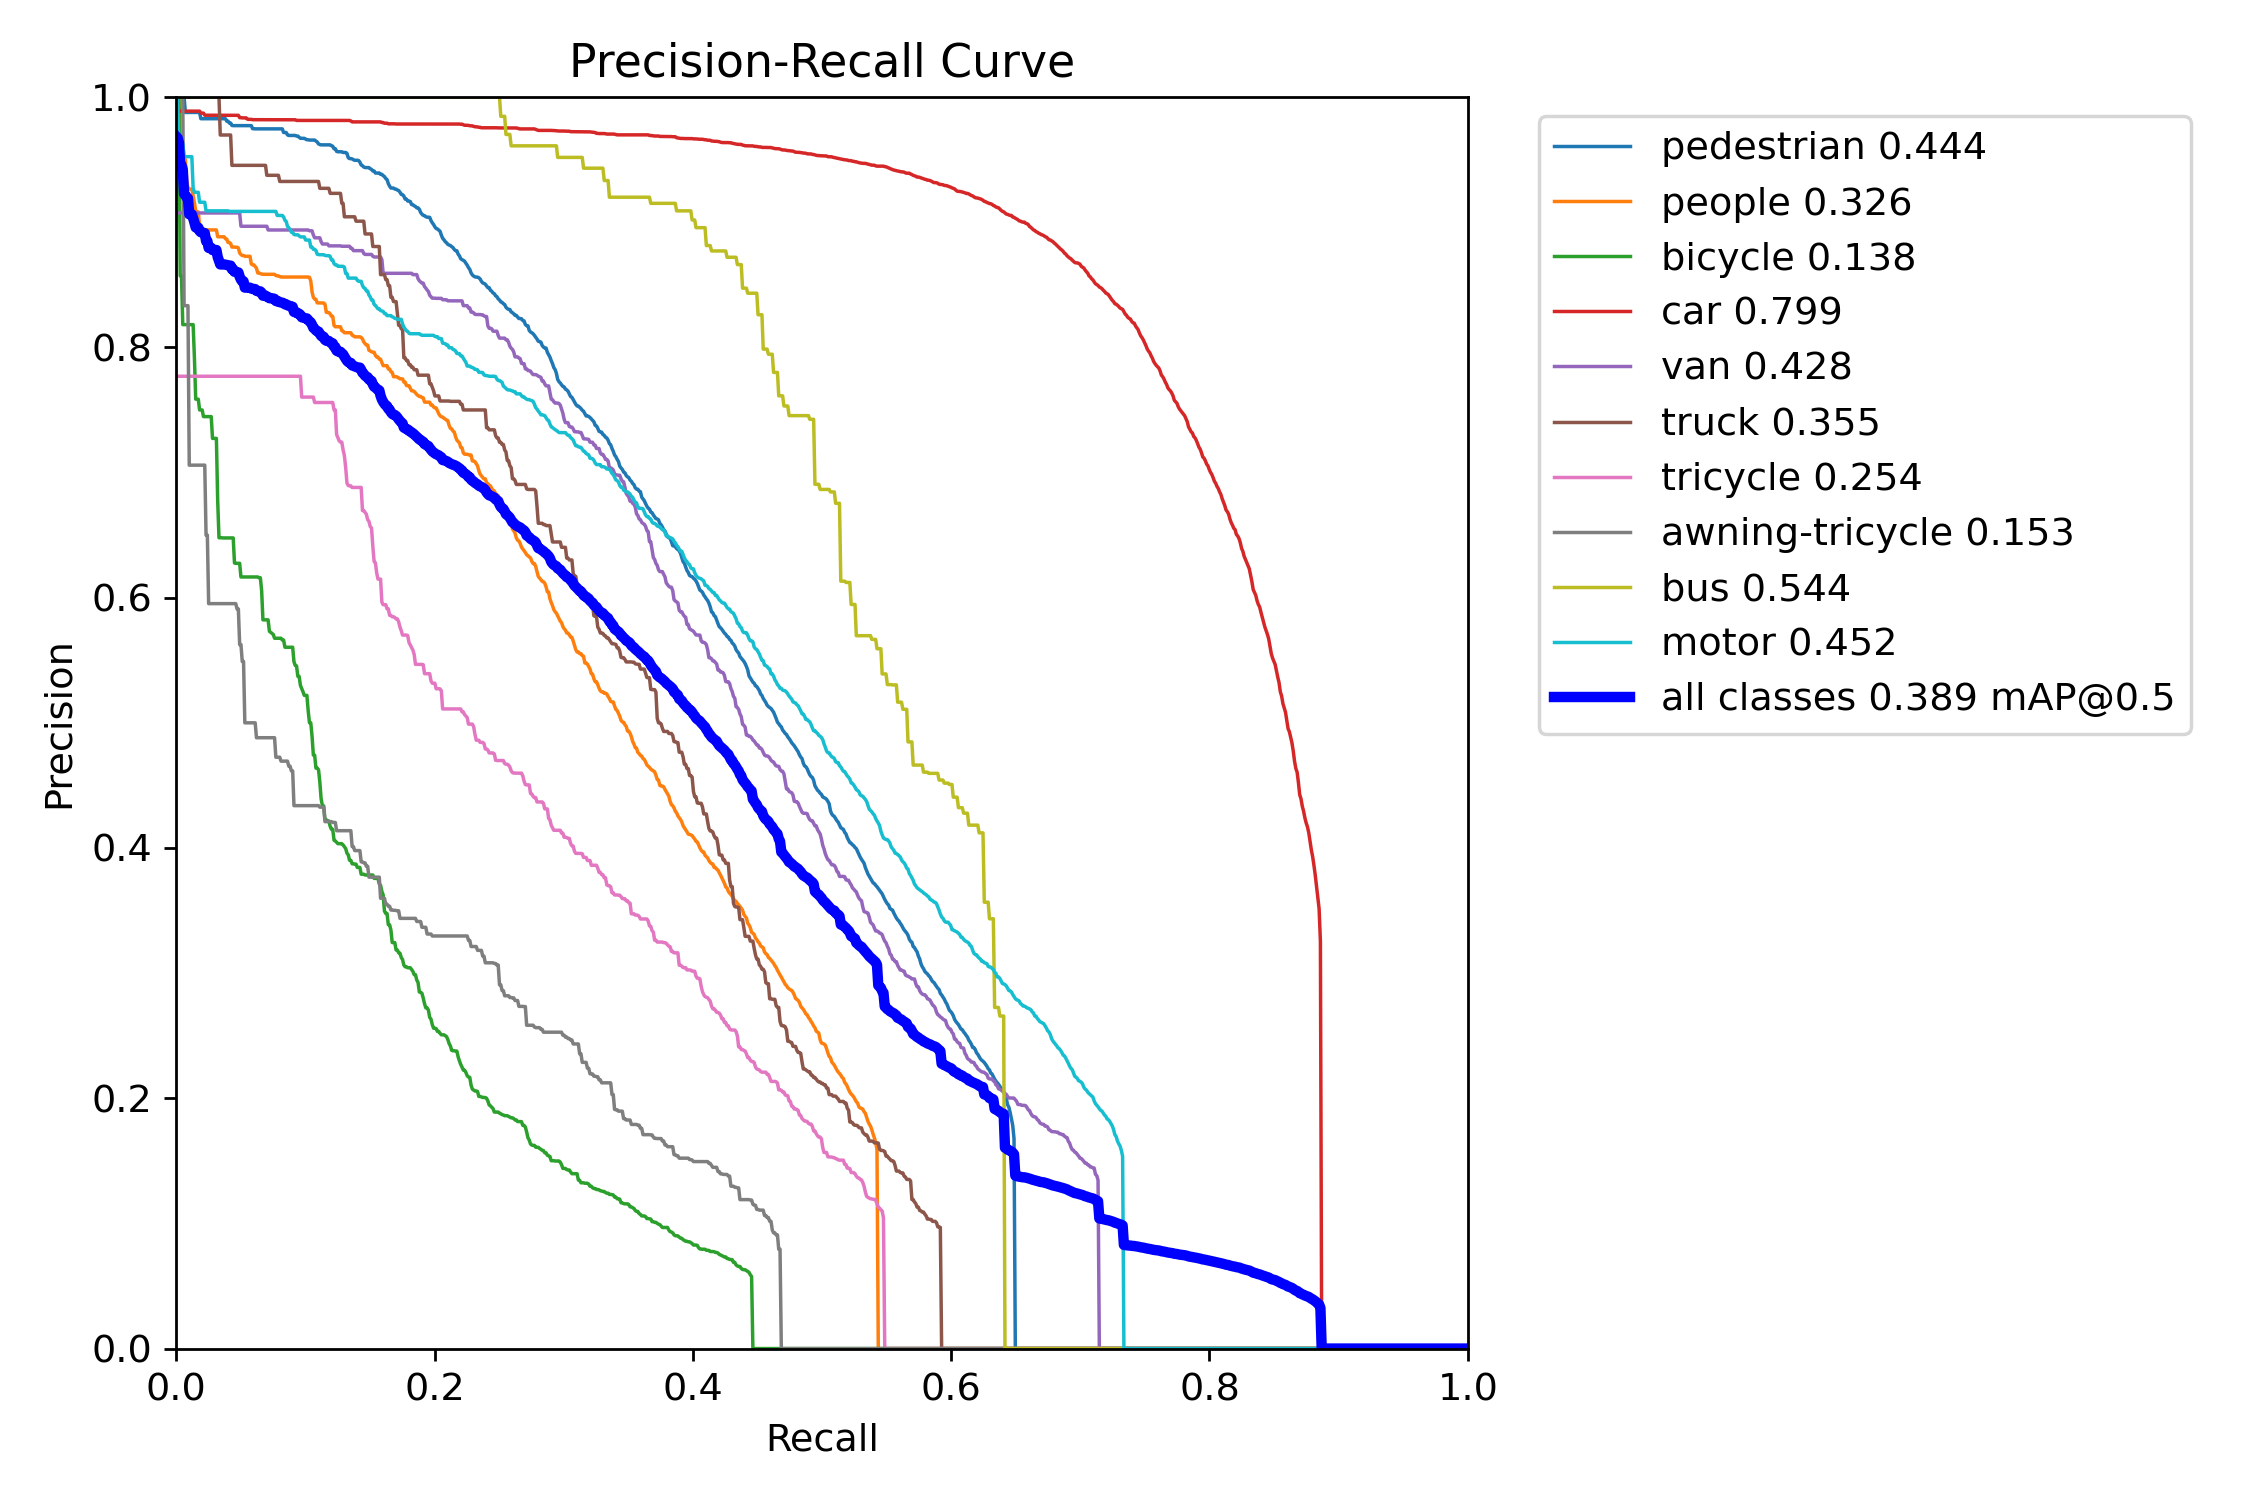
| mAP at IoU 0.50 | 0.389 |
| mAP at IoU 0.50–0.95 | 0.231 |
These values are transcribed from the project README and accompanied by saved evaluation plots. Training and evaluation have not been rerun for this portfolio. The record describes ten-class model validation; these are not established as metrics for the three-class display subset.
Pipeline & implementation
The local project includes scripts for dataset exploration, training, image inference/counting, and video tracking. The recorded training configuration uses 50 epochs and 960-pixel images with automatic batch sizing and mixed precision.
Limits & next steps
Small or occluded people may be missed, and similar vehicle types can be confused. Counts are image-based; full unique-object counting across a video is not implemented. The repository does not include trained weights.
Next steps include repeatable evaluation with an explicit split and class mapping, subgroup error analysis, a counting-error metric, and a recorded hardware-specific speed benchmark.